
Accuracy budget
Positioning accuracy, repeatability and resolution targets, plus the error share allocated to feedback versus mechanics.
TECHNOLOGY / ENCODER FEEDBACK SELECTION
Compare optical and magnetic encoder feedback for precision motion stages: resolution, accuracy, contamination, vibration, interfaces and acceptance evidence.
Published
DIRECT ANSWER
Optical encoder feedback should be the default choice when a precision stage must hold sub-micron positioning, because a micron-scale optical scale with interpolation delivers nanometer-class resolution and sub-micron-per-meter accuracy that magnetic sensing cannot match. Magnetic encoder feedback is the pragmatic choice when the dominant requirement is survival—dust, oil mist, coolant, shock and wide temperature swings—where it trades roughly an order of magnitude in accuracy for dramatically better environmental tolerance, larger mounting gaps and lower cost.
Treat the decision as an accuracy-versus-environment budget, not a technology ranking. Write down the positioning and repeatability target, the contamination and vibration the stage will actually see, the allowable installation tolerances, and the interface the controller supports. Then require both technologies to quote against the same brief, and close the selection with measured error-map evidence taken on the real stage, not with catalogue resolution numbers.
ENGINEERING CONTEXT
Buyers choosing position feedback for a precision motion stage face two technologies that excel in opposite conditions. Optical encoders dominate sub-micron accuracy in clean environments but are sensitive to contamination, gap and alignment. Magnetic encoders tolerate dirt, shock and temperature extremes, but their pole pitch and interpolation set a coarser accuracy ceiling. The selection must weigh accuracy targets against environmental reality, installation tolerances and total cost of ownership.
Discuss your requirement ↗CRITICAL REQUIREMENTS
Positioning accuracy, repeatability and resolution targets, plus the error share allocated to feedback versus mechanics.
Dust, oil mist, coolant, ferrous debris, vibration, shock and the temperature range the encoder must survive.
Achievable scale flatness, readhead gap tolerance, alignment skills and service access on the actual stage.
Signal interface, interpolation electronics, cable length, EMC plan and controller compatibility.
BUYER MATRIX
Give every shortlisted supplier the same process definition and request configuration-specific proof.
| Criterion | Optical encoder | Magnetic encoder |
|---|---|---|
| Resolution | Nanometer-class after interpolation of micron-scale optical pitch | Sub-micron to micron after interpolation of 0.5–2 mm pole pitch |
| Accuracy over travel | Typically ±0.5 µm/m class on glass scales; low thermal drift | Typically several µm/m, set by pole pitch accuracy and interpolation non-linearity |
| Contamination tolerance | Sensitive; dust, oil mist and condensation degrade the optical path | High; non-ferrous debris and oil do not block magnetic sensing |
| Gap and alignment | Tight readhead gap, typically tens to hundreds of microns, careful alignment | Forgiving gaps up to the millimeter class, tolerant of tilt and shaft play |
| Vibration and shock | Glass scales and precision optics need shock-aware mounting | Solid-state sensing survives high shock and vibration levels |
| Cost of ownership | Higher unit cost plus sealing and cleaning discipline in dirty shops | Lower unit cost and minimal maintenance in harsh environments |
Position feedback is one term in a larger error budget that also includes guideway geometry, drive dynamics, thermal expansion and structural compliance. Before comparing technologies, quantify what the feedback subsystem must contribute. If the application is a lithography stage, a metrology machine or an optical inspection platform that must hold sub-micron positioning over hundreds of millimeters, the feedback error share is usually forced below a micron, and an optical linear encoder is effectively the only realistic candidate.
If the requirement is tens of microns or better repeatability on a machine that lives near coolant mist, wood dust or metal chips, the feedback question changes shape. Magnetic encoders deliver repeatable micron-class feedback in conditions that would blind an optical readhead, and the accuracy ceiling of a few microns per meter is then well inside the overall machine budget. Writing the budget down first prevents the two classic mistakes: overpaying for optical precision a rough machine cannot exploit, and under-speccing feedback for a stage that deserves better.
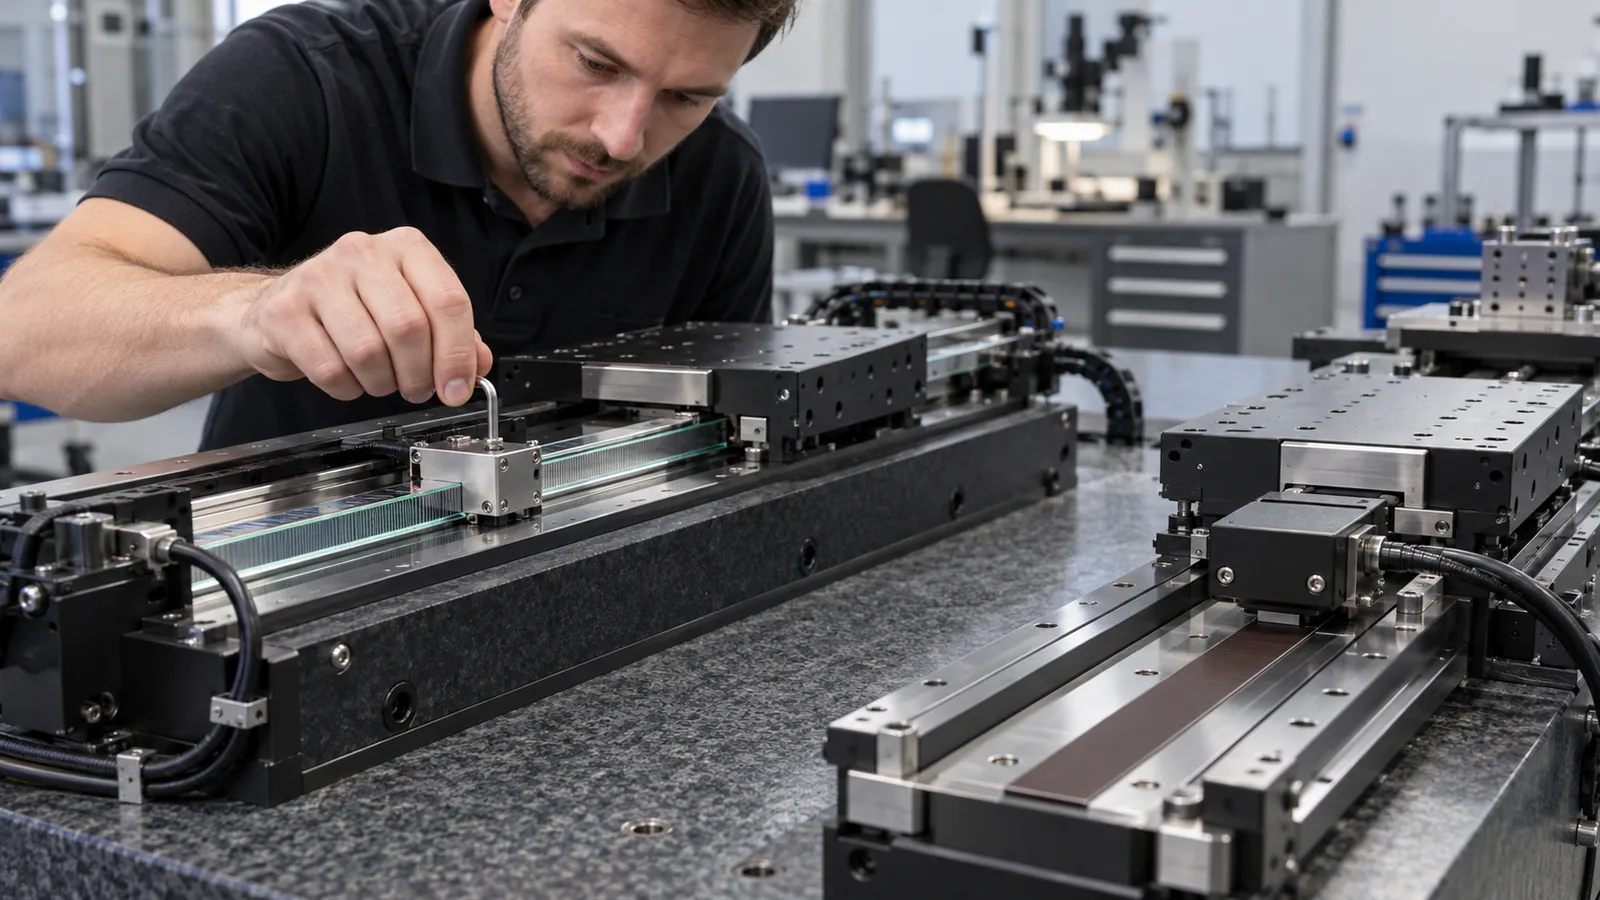
An optical encoder measures displacement with light. A readhead illuminates a glass or chrome-on-steel scale carrying micron-scale graduations, and photodetectors convert the transmitted or reflected light into periodic sine and cosine signals. Interpolation electronics subdivide each signal period, so a scale with a few-micron pitch reaches nanometer-class resolution. Because glass has a very low thermal expansion coefficient and the graduation accuracy is tightly controlled, total accuracy in the ±0.5 µm per meter class is achievable in a clean, temperature-controlled installation.
A magnetic encoder senses field changes instead of light. Hall, AMR, GMR or TMR elements read alternating magnetic poles on a magnetized strip or wheel, commonly with a 0.5–2 mm pole pitch, and interpolation electronics derive position from the field pattern. Modern ASIC interpolation holds non-linearity to tens of nanometers, but the underlying pole pitch and its bonding accuracy set an overall accuracy typically quoted at a few microns per meter. The sensing principle is also the robustness story: magnetic field sensing is indifferent to non-ferrous dust, oil and moisture that would scatter or block an optical path.
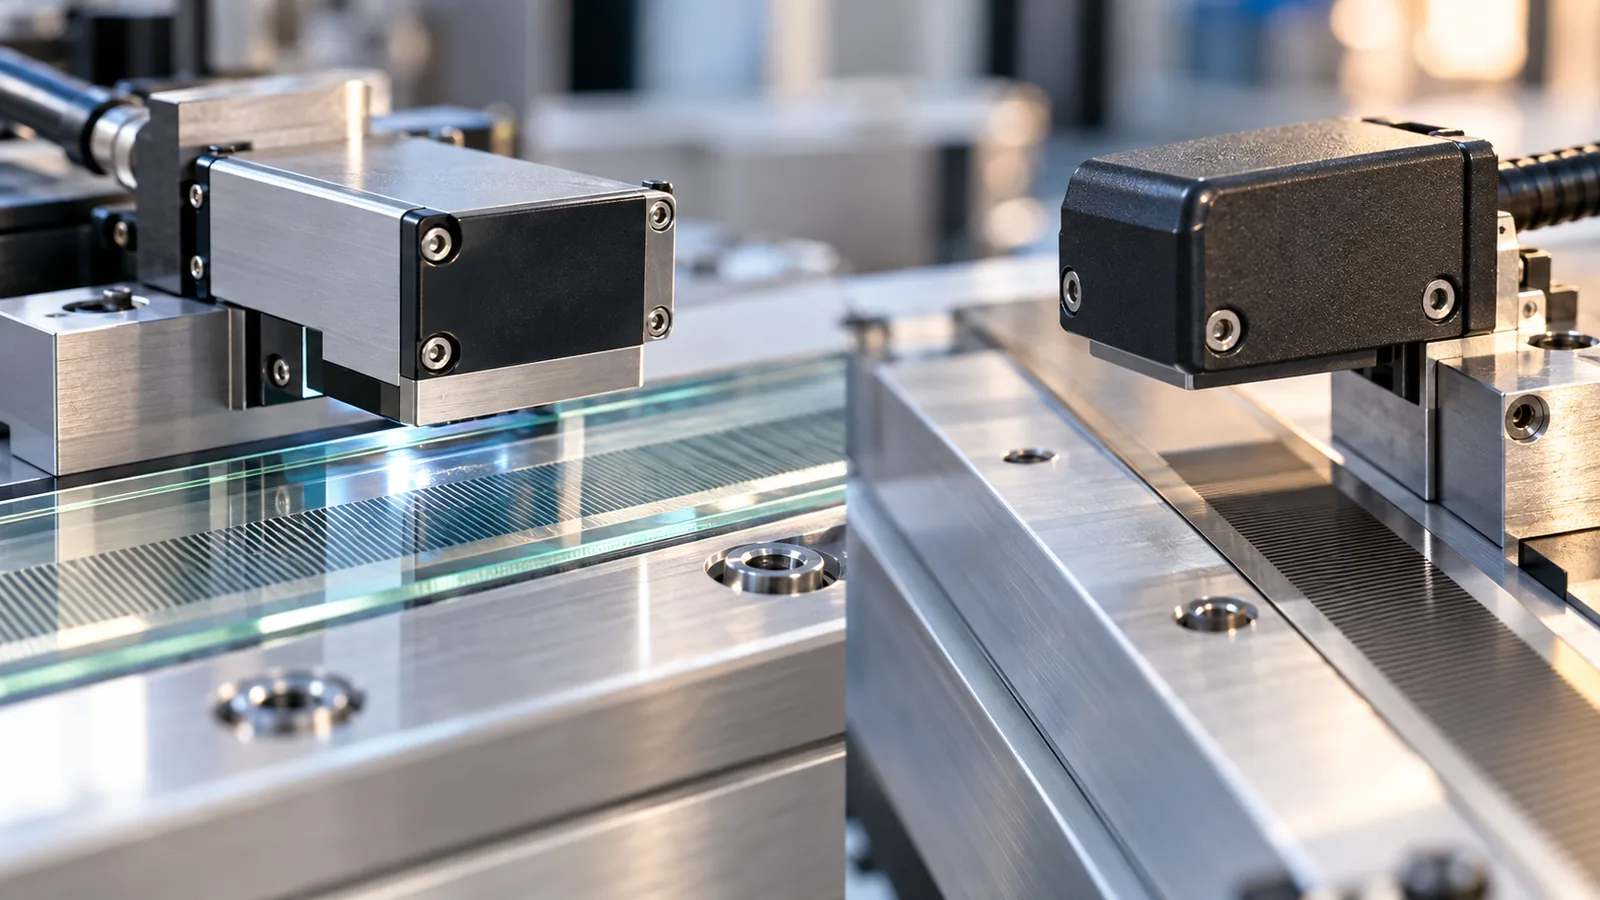
Environment is where the two technologies diverge most. Optical encoders are precision instruments: dust, oil mist, condensation and misalignment degrade signal quality, so they need sealed housings, conditioned air or disciplined maintenance in anything beyond a cleanroom or a tidy lab. Industry comparisons consistently note that optical systems deliver the highest accuracy but demand cleaning routines and careful sealing, while magnetic systems keep counting through grime that would interrupt an optical signal.
Magnetic feedback has two weaknesses of its own. Ferrous chips can cling to the magnetic scale and locally distort the field, so wipers or cover foils are needed near machining operations, and strong external magnetic fields require shielding awareness. Temperature is the other axis: magnetic sensing typically operates from around −40 °C to well above 100 °C, while optical assemblies are bounded by LED life, condensation risk and adhesive limits. A stage in a metrology lab and a stage on a factory floor may therefore justify opposite answers despite similar positioning numbers on paper.
Installation effort is a hidden cost that often decides the outcome. An optical scale demands flat mounting surfaces, controlled twist, and a readhead gap commonly in the tens-to-hundreds-of-microns range with milliradian-class tilt tolerance. Skilled assembly and careful commissioning are assumed. Magnetic tape scales bond quickly to long axes, tolerate gaps up to the millimeter class and accept significantly more yaw, pitch and roll, which makes them attractive for long strokes, retrofits and machines with residual mechanical imperfection.
That tolerance difference cuts both ways. A forgiving gap hides real errors: if the tape wanders relative to the measurement line, the accuracy specification quietly degrades. An optical installation is less forgiving, but it enforces the mechanical discipline that a precision stage needs anyway. Compare the two technologies with the installation procedure, required tooling and acceptance checks in hand, and prefer the one whose demands your assembly process can hold repeatably—not only the one whose datasheet numbers look best.
Ask each supplier to state the limits that govern installation quality on your frame, and ask how those limits are verified after assembly. Comparable answers make the tradeoff explicit.
Both technologies feed the same family of interfaces—1 Vpp analog, quadrature, and serial protocols such as BiSS and EnDat—so the controller rarely decides the technology alone. What does differ is signal quality at the working condition. Optical sine signals from a clean scale are crisp and interpolate cleanly; a contaminated or misaligned optical path shows amplitude loss and distortion that become interpolation error and velocity ripple. Magnetic signals are robust but carry larger periodic interpolation error, which matters to smooth motion at low speed.
Plan the whole signal chain, not just the sensor: cable routing away from motor drives, grounding, connector hygiene and, for high-count interpolation, the controller's edge-rate and filter settings. Also confirm lifecycle support for both candidates—electronics revisions, spare scale availability and firmware continuity—so a five-year machine program does not inherit an obsolete feedback part. The EMC and interface discipline is identical for either technology and should be part of the acceptance package.
Whatever the datasheets promise, the decision should end with a measurement on the real stage. Run both candidates—or at least the shortlisted favorite—through the same error-mapping procedure, ideally referenced to a laser interferometer, and record positioning error over travel, repeatability, reversal error and velocity smoothness at production speeds. A magnetic encoder that meets the budget on your machine is a better answer than an optical encoder whose accuracy cannot survive your environment; the reverse holds equally.
Document the test conditions—temperature, warm-up state, mounting configuration and controller settings—so the result is auditable and can be repeated after service. SENFU supplies optical encoder feedback for precision stages and lithography equipment, and the same evidence-first logic applies to every feedback technology comparison: state the budget, control the environment, measure the installed result, and keep the raw data.
CONCLUSION
Optical and magnetic encoder feedback solve different problems. Optical sensing wins the accuracy contest outright—nanometer-class resolution and sub-micron-per-meter accuracy from a clean, well-mounted glass or steel scale—while magnetic sensing wins the survival contest, holding micron-class repeatability through dust, shock, and temperature extremes that would disable an optical readhead. The right choice falls out of an honest error budget combined with an honest description of the operating environment.
Compare both technologies against the same brief: accuracy targets, contamination and vibration reality, installation tolerances your assembly can hold, interfaces your controller supports, and an installed-performance test referenced to independent metrology. SENFU can review your stage requirement against the optical encoder portfolio and help define the acceptance evidence before you commit.
EVIDENCE CHECKLIST
FAQ
In principle yes, and in practice the gap is large. Optical scales with micron pitch reach nanometer-class resolution and sub-micron-per-meter accuracy, while magnetic pole pitch and interpolation non-linearity typically cap accuracy at a few microns per meter. The practical question is whether your stage and environment can realize the optical advantage.
When survival dominates precision: dusty or oily environments, coolant spray, high shock and vibration, wide temperature ranges, or installations where a large gap and fast tape bonding matter more than the last micron of accuracy. Magnetic feedback also lowers maintenance burden in hard-to-access machines.
They degrade before they fail: contamination on the optical path reduces signal amplitude and quality, which becomes interpolation error and eventually signal dropout. Sealed housings, air purges and cleaning discipline extend optical encoder service in mild contamination, but heavy debris environments usually favor magnetic sensing.
Optical readheads typically need gaps in the tens-to-hundreds-of-microns range with tight tilt tolerance, while magnetic sensors tolerate gaps up to the millimeter class and noticeably more yaw, pitch and roll. The forgiving gap simplifies installation but must not be used to paper over scale alignment errors.
Yes. Both feed 1 Vpp analog, quadrature and serial absolute interfaces such as BiSS and EnDat, so the controller choice rarely dictates the sensing technology. Evaluate signal quality at your working speed and the EMC quality of the cable plan instead.
Ask for an installed-performance error map on a representative stage: positioning error over travel, repeatability, reversal error and velocity smoothness, with temperature, mounting and controller settings recorded. Add the supplier's installation limits and lifecycle support commitment, and keep the raw measurement data.
AUTHORITATIVE SOURCES
TECHNICAL REVIEW
Send the application, critical parameters and any drawing or process information available.
Discuss your application ↗